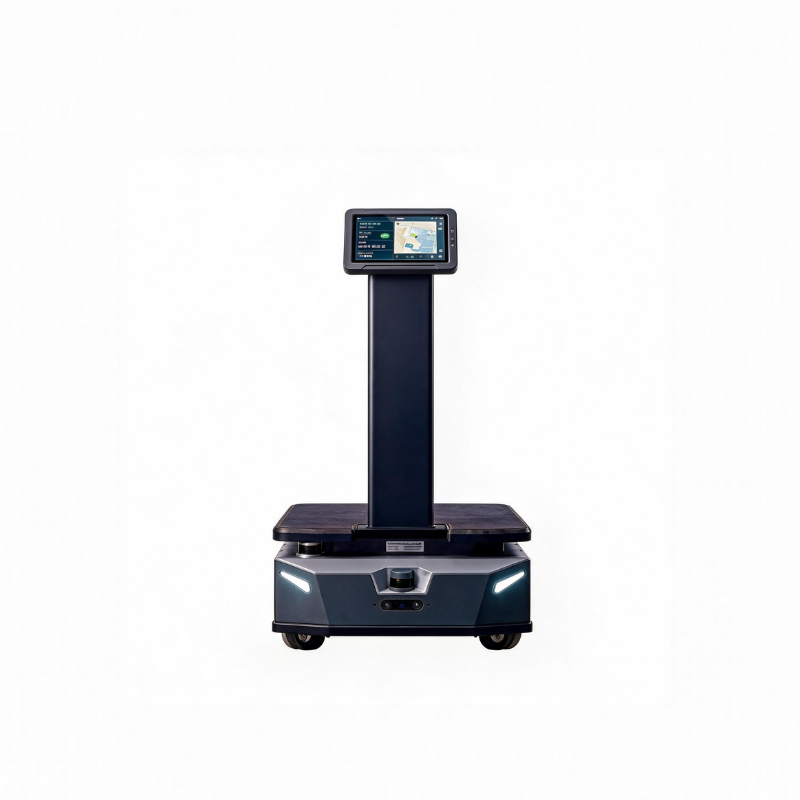
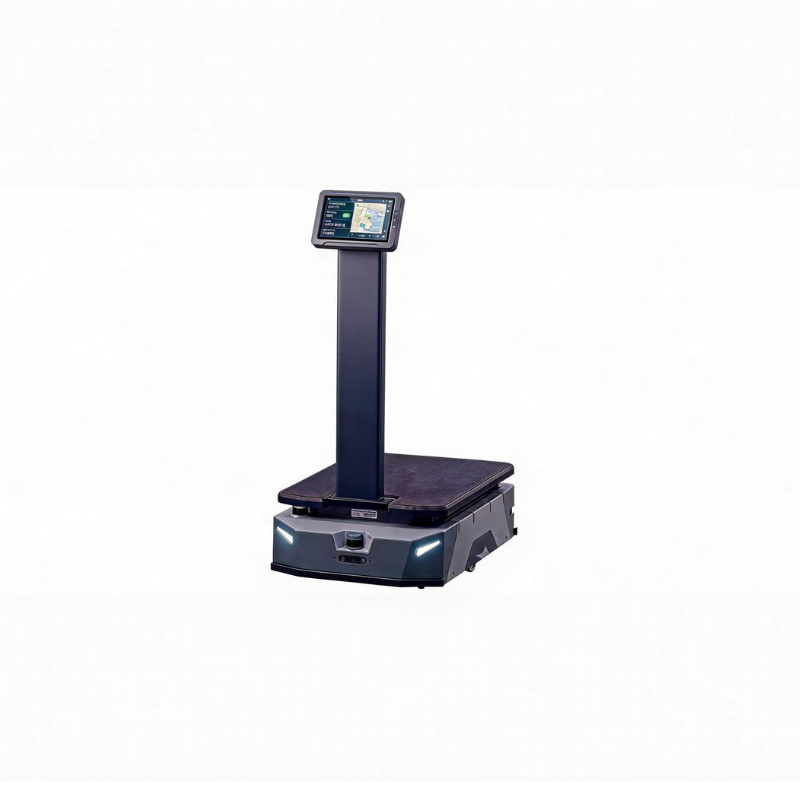
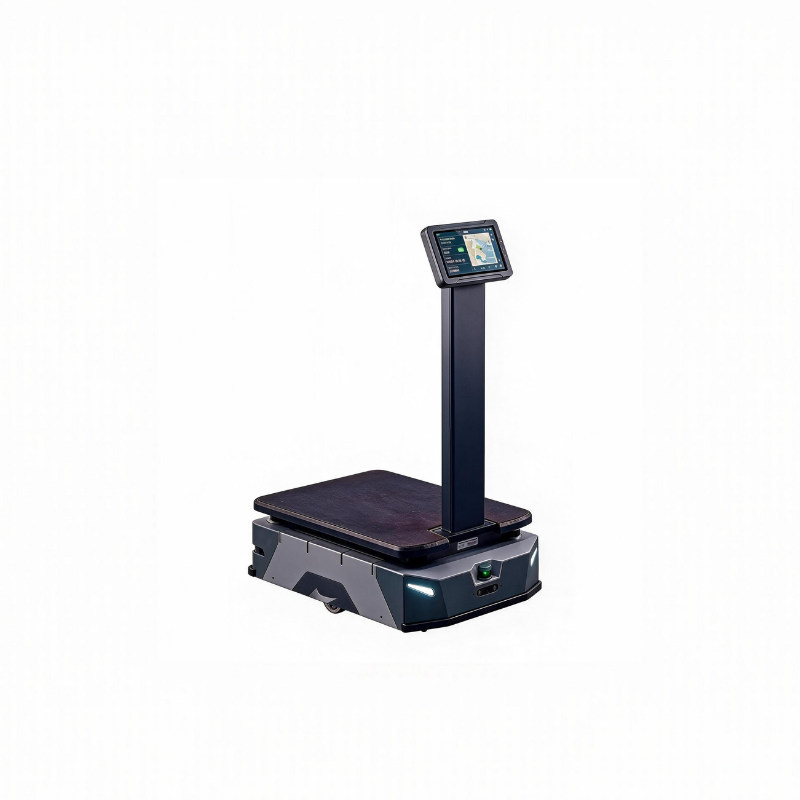
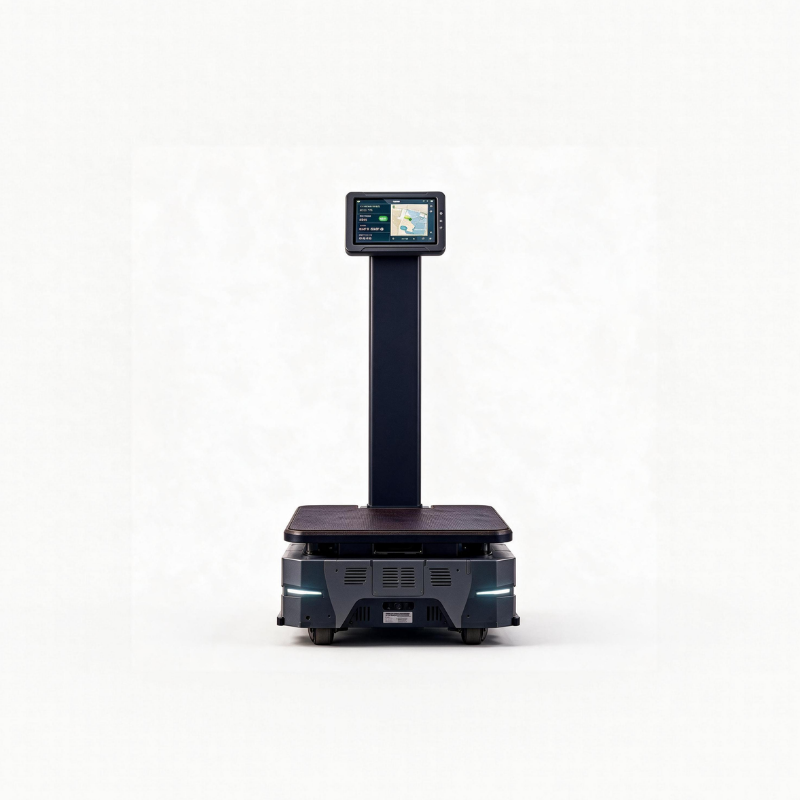
LPT-A300 Autonomous Mobile Robot
Compact autonomous mobile robot carrying 300 kg loads with SLAM 2.0 navigation across production and logistics areas.
可选参数
Production Line Material Handling Expert
The LPT-A300 is a compact autonomous mobile robot for intralogistics. It carries loads up to 300 kg at 0.3–1.2 m/s with ±5 cm positioning accuracy under SLAM 2.0 navigation. Dual front-and-rear LiDARs give 360° perception for safe obstacle avoidance, while depth vision detects static and dynamic obstacles. Automatic charging and multi-robot collaboration with MES, WMS, and LIMS enable 7×24 h unmanned material flow.
Technical Specifications
- SLAM 2.0: Real-time LiDAR mapping with centimeter-level positioning and smart path planning
- Dual LiDAR: Front and rear LiDARs deliver 360° obstacle and terrain detection
- 300 kg Payload: Carries 300 kg loads at 0.3–1.2 m/s adjustable speed
- Fleet Ready: Multi-robot scheduling integrates with MES, WMS, and LIMS systems
Complete Technical Specifications Table
| Parameters | Description |
|---|---|
| Model | LPA-300 |
| Product Name | Material Handling & Inspection Robot A300 |
| Overall Dimensions (L × W × H) | 908 mm × 560 mm × 1,240 mm |
| Platform Dimensions (L × W) | 699 × 548 mm |
| Net Weight | 120 kg |
| Body Material | Sheet metal |
| Rated Load | 300 kg |
| Lift Height | 70 mm |
| Lift Speed | 5 mm/s |
| Ingress Protection Rating | Vehicle IP34, battery pack IP30 |
| Operating Environment | Indoor, clean environment, free of corrosive gases |
| Operating Temperature | −10°C to 60°C |
| Storage Temperature | 0°C to 50°C |
| Charging Temperature | 5°C to 50°C (indoor) |
| Screen | 10.1-inch screen, 1280 × 800 resolution |
| Operating System | Android |
| WiFi | 2.4G WiFi router, supports 802.11a/b/g/n/ac |
| Bumper Strip | Front of vehicle |
| Navigation Modes | Obstacle bypass / obstacle stop / autonomous track driving with strict track following |
| Travel Speed | 0.3–1.2 m/s, adjustable |
| Minimum Aisle Width | 76 cm |
| Climbing Angle | 5° |
| Maximum Floor Gap Width | ≤ 3.5 cm |
| Threshold Crossing Height | 1 cm |
| Minimum Ground Clearance | 4 cm |
| Minimum Elevator Passage Width | ≥ 80 cm |
| Minimum Gate Passage Width | ≥ 80 cm |
| Operating Noise | ≤ 50 dB |
| Frequency | 30 Hz |
| Absolute Position Accuracy | ± 5 cm |
| Heading Accuracy | ± 4° |
| Battery | 48V 20Ah LiFePO4 Runtime: 6 hours; 7 × 24h operation achievable with charging dock deployment Standby time: 12 hours Charging: automatic return at low battery; manual return command and external charger also supported Full charge time: ≤ 2 hours |
| Charging Dock | Input: AC 220V, 50/60 Hz Dimensions: 365 mm × 360 mm × 180 mm Weight: 13 kg Output: 54.2V / 10.0A fast charging |
| Mapping Area | Maximum mapping area: 500 m × 500 m Scan range: 360° |
| Map Resolution | 5 cm |
| Map Editing | Stops, charging dock, virtual walls |
| LiDAR × 2 | Detection range: 360° (full vehicle visibility) Detection distance: 0.05–30 m @ 90% reflectivity; 0.05–10 m @ 10% reflectivity Measurement rate: 30,000 measurements/s Scan frequency: 15 Hz |
| Depth Camera × 1 | Position: 1 at front, for low-lying and hollow object detection Detection distance: 0.04–2 m |
| Attitude Sensor × 1 | Pitch: ± 90°; Roll: ± 180°; Heading: ± 180° Operating temperature: −40°C to 85°C |
| Ambient Lights | 4 units: 2 at front, 1 at each rear corner |
| Emergency Stop Buttons | 3; chassis can be pushed manually when engaged |
Material Delivery for Every Scenario