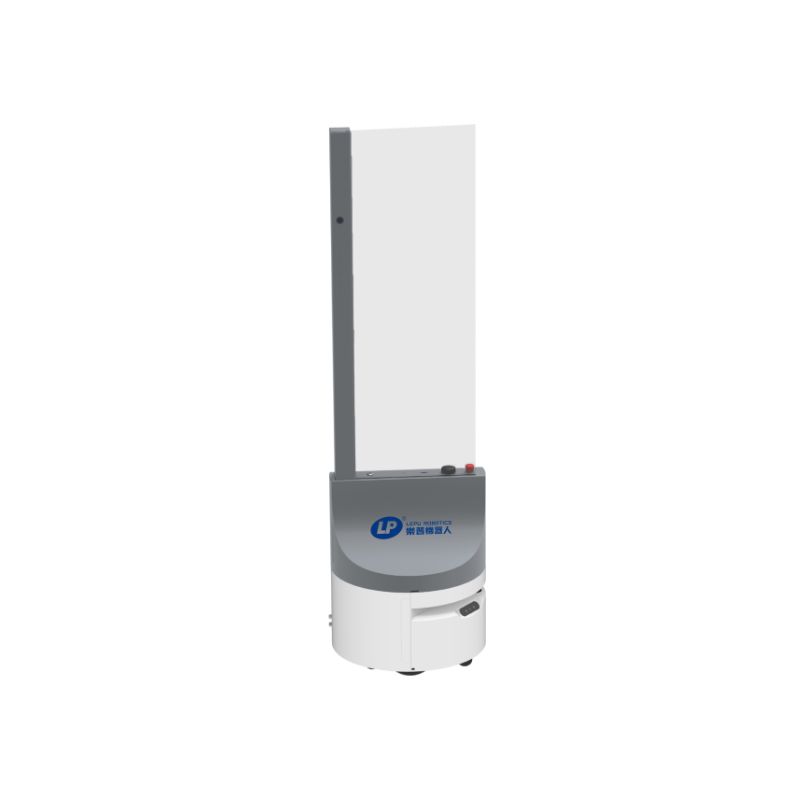
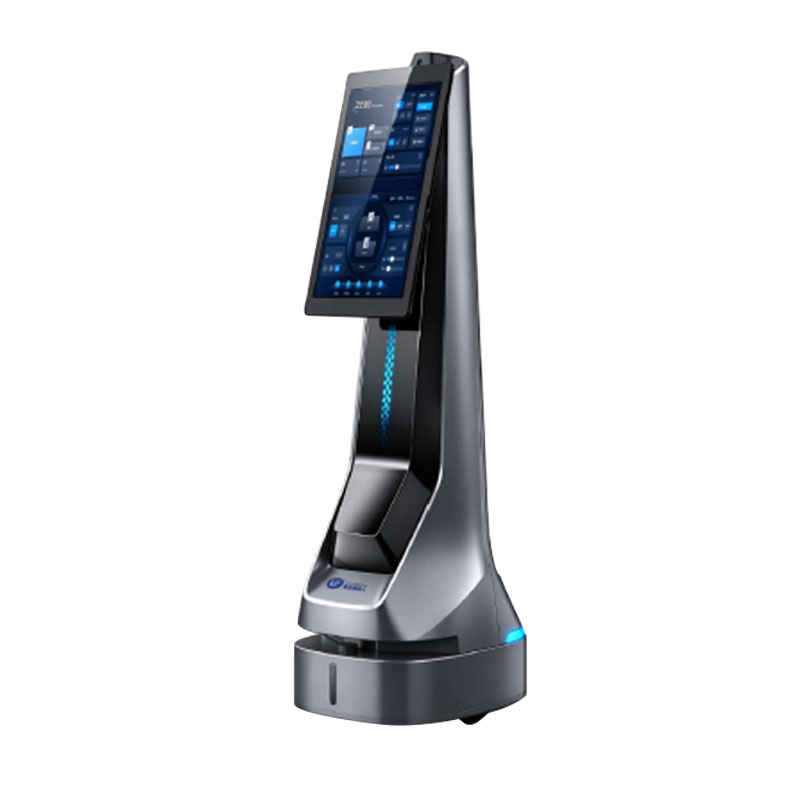
LPS-D20 Reception Service Robot
Autonomous reception robot with intelligent voice interaction and guidance for front desks, hotels, and hospitals.
Optional Parameters
A Smart Front Desk That Greets
The LPS-D20 is an autonomous reception robot that greets visitors, answers questions, guides tours and displays information for enterprises. Natural-language voice interaction handles consultations intelligently, while vision-LiDAR fusion navigation moves it safely around lobbies. Automatic low-battery charging and remote task deployment keep services running with minimal maintenance.
Core Advantages
- Voice Interaction: Natural-language Q&A with intent recognition and intelligent consultation
- Autonomous Navigation: Vision-LiDAR fusion for localization, path planning and obstacle avoidance
- Auto Charging: Returns to the charging station automatically, no manual intervention
- Remote Deployment: Remote configuration and task setup for rapid, flexible launch
Complete Technical Specification Table
| Parameters | Description |
|---|---|
| Model | LPS-D20 |
| Product Name | Service Robot D20 |
| Screen Size | 21.5 inch |
| Overall Dimensions (L × W × H) | 420 × 503 × 1,442 mm |
| Machine Weight | 52 kg |
| Machine Power | < 80 W |
| Body Material | Sheet metal + ABS |
| Motion Mode | Two-wheel differential drive |
| Navigation Mode | 2D LiDAR navigation |
| Battery Capacity | LiFePO4, 24V 10Ah |
| Runtime | 8 hours |
| Charging Time | 3 hours (10%–90%) |
| Charging Method | Automatic / Manual charging |
| Battery Cycle Life | ≥ 2,000 cycles |
| Operating Temperature & Humidity | 0°C to 40°C, 20%–80% RH |
| Display Size | 21.5 inch |
| Backlight Type | LED |
| Display Resolution | 1920 × 1080 |
| Aspect Ratio | 16:9 |
| Brightness | ≥ 250 cd/m² |
| Viewing Angle | 89 / 89 / 89 / 89 |
| Response Time | 8 ms (max) |
| Response Speed | ≤ 3 ms |
| Color Depth | 1.07B (10-bit), 72% NTSC |
| Capacitive Touch | G+G capacitive, 10-point touch |
| Touch Life | ≥ 50,000 touches |
| Operating System | Android |
| CPU | Octa-core 64-bit (4 × Cortex-A76 + 4 × Cortex-A55), 2.4 GHz |
| RAM | 8 GB |
| Storage | 64 GB |
| GPU | ARM Mali-G610 MP4 quad-core |
| Application Software | Single-robot / multi-robot fleet scheduling software |
| Camera | 2 MP, 1/3″ |
| Camera Resolution | 1920 × 1080 @ 30 fps |
| Microphone Type | 4-microphone ring array |
| Sampling Bit Depth & Rate | 16-bit, 16 kHz |
| Microphone Noise Handling | Supports DNN noise reduction, AEC, AES, AGC, and microphone array algorithms |
| Signal-to-Noise Ratio | 55 dB (94 dB SPL @ 1 kHz, A-weighted, typical) |
| Sensitivity | −38 dBV/Pa (94 dB SPL @ 1 kHz) |
| Passability | No steps; flat floor only |
| Minimum Passage Width (cm) | 80 |
| Mapping Area (m²) | 500–3,000 |
| Navigation Position Accuracy (cm) | ± 5 |
| Navigation Angle Accuracy | ± 4° |
| Travel Speed (m/s) | ≤ 1, adjustable |
| Standard Configuration | Robot × 1, charging dock × 1 |
Smart Reception for Every Venue